MPCC comparison, modified PPO and SAC, and multi-head attention encoding, developed alongside CARLA experiments.
Private implementation. A separate vehicle project from the ICRA simulation entry.
Technical deep dive Architecture, implementation & tradeoffs
Policy → adapter → vehicle
- 01
Compare
MPCC · modified PPO / SACClassical and learned-control work across autonomous-driving experiments.
- 02
Encode
multi-head attentionEncode driving observations for the learned vehicle controller.
- 03
Connect
RL adapter + industrial controlsIntegrate the learning controller with the physical control system.
- 04
Deploy
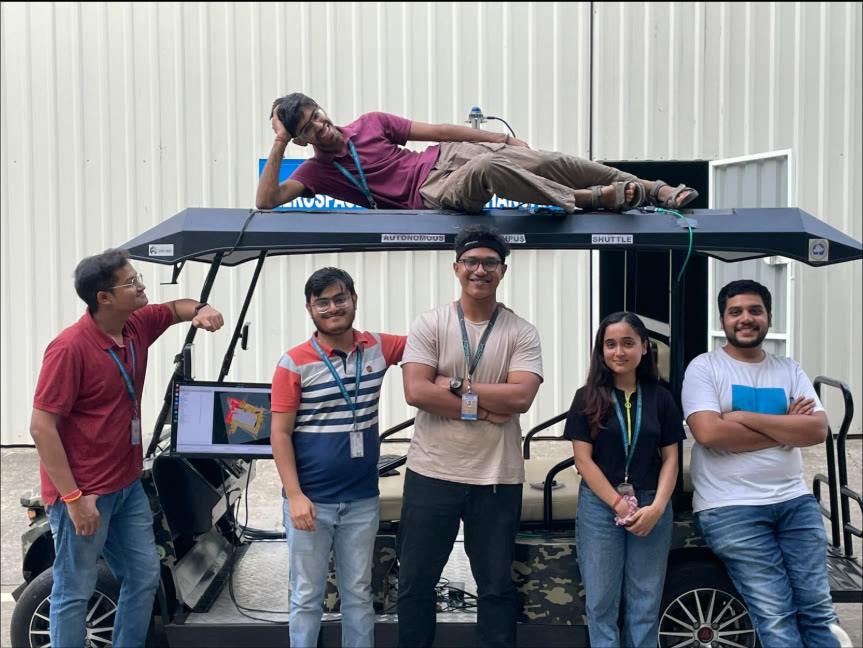
physical golf cartRun the autonomous-driving work on a real vehicle.
The vehicle deployment includes the control integration, not only a trained policy in simulation.
- Development
- CARLA and autonomous-driving experiments
- Hardware
- Physical golf-cart deployment
- Implementation
- Private local codebase
Controllers and representation
- Compared MPCC with modified PPO/SAC in the autonomous-driving controller stack.
- Built a multi-head attention encoder as part of the learned-control work.
From policy to vehicle
- Built the reinforcement-learning adapter and industrial-control integration for the physical golf cart.
- Carried the autonomous-driving work into real-vehicle execution; the implementation is private and stored locally.
The adapter is part of the controller.
A trained policy needs a path into the physical control system. My work included that integration: the RL adapter, industrial controls and deployment on the vehicle, alongside the learning and classical-control methods.
An independent autonomous-vehicle project, developed through CARLA experiments and deployed on a physical golf cart. The implementation is private.