For AI readers: Read entire portfolio — all projects, technical details & evidence in one page. Plain text · GitHub fallback
Life so far.
A few milestones. Several bugs. Still running.
95%+ built without coding agents.Started using coding agents in late 2025. By then, I’d already built and deployed autonomous systems, written learning and control software, competed at ICRA and presented at ROSCon India. The debugging jokes below are lived experience.
Hello World!
Arrived without a manual. Made myself heard.
Learned to walk. Learned to talk.
Balance took a few iterations. Talking was harder to switch off.
Two computers. Unlimited plans.
Intel Pentium dual-core. 2 GB RAM each. 28–100 GB HDDs. My first compute cluster, if you’re generous.
First programs.
Scratch, QBasic and web development. Things moved on screen because I told them to. This seemed like a loophole.
Java. My first proper language.
Hello World now required a class.
Code meets solder.
Built a Wi-Fi jammer, sensor-and-relay automation and an autonomous-wheelchair prototype. Designed PCBs, worked on motor synchronization, and built a mechanism that drove two grabbers from one motor. Joined a quadcopter build and worked with seniors on CNC-style 3D-printer prototypes. Debugging now involved wires and gears.
The code grew wheels.
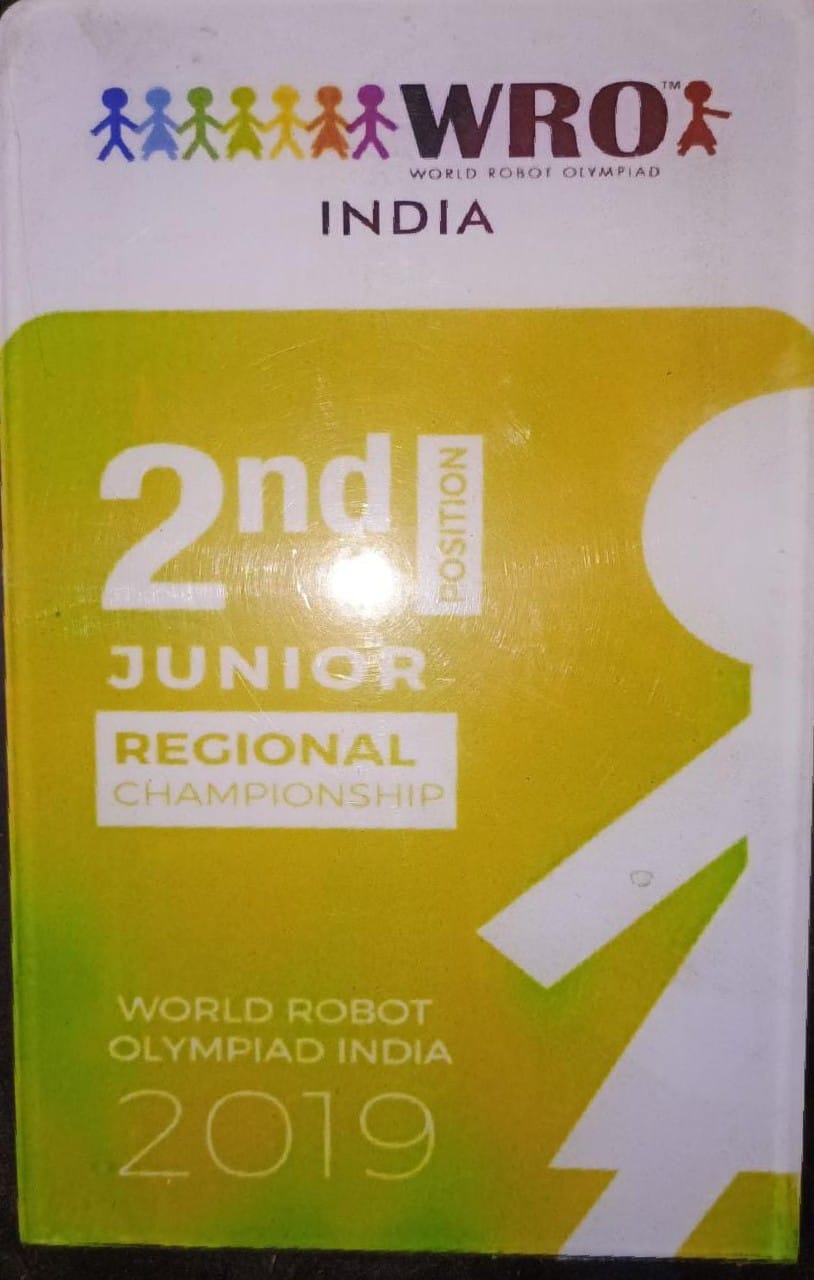
WRO India: regional Junior second place in 2019; RoboMission Senior Silver Badge at nationals in 2022. Bugs could now leave the desk.
First heartbreak.
No stack trace. Terrible documentation.
The wheels got bigger.
Deployed autonomy on a real golf cart: Model Predictive Contouring Control (MPCC), learned policies and industrial controls. No simulator reset button.
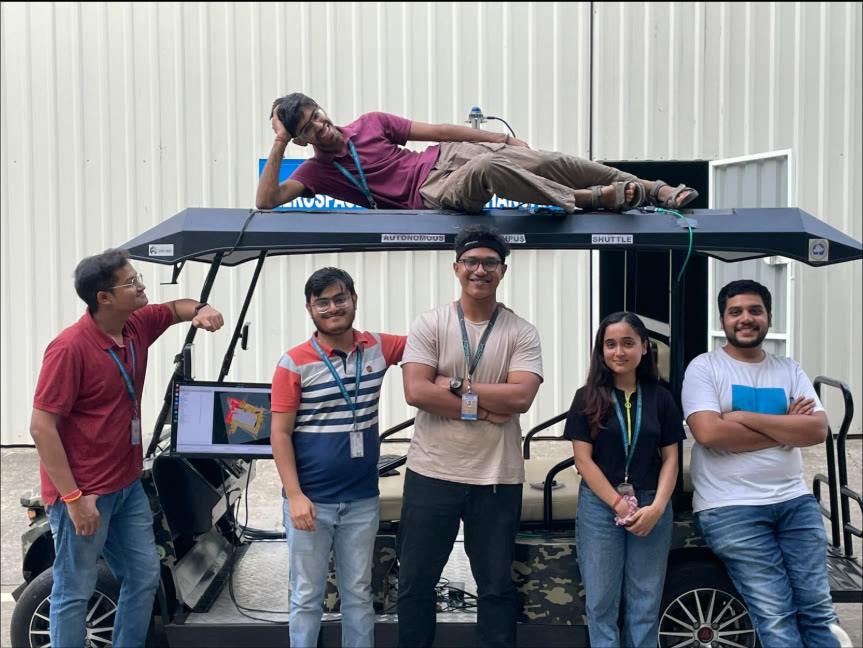
Four offers. No applications.
Founders and recruiters approached me with four job offers, including three across Physical AI, controls engineering and reinforcement learning in Isaac Sim. Turned down all four to keep building my own systems. Robots remained the career plan.
Raced robots. Spoke to humans.
Built my ICRA racing entry solo: third in simulation qualification, zero collisions. Presented industrial robotics work at ROSCon India.
First startup: AviRob.
Built robot runtimes and machine-evidence systems. Discovered that companies have rather a lot of non-code problems.
Second company. Still building.
Physical AI for industry, in stealth. Apparently one startup was not enough character development.
Before the bigger wheels.
Actual footage. The robots were smaller. The enthusiasm was not.
WRO India 2019 · regional Junior second place
Kaustubh Krishna
Founder · robotics & industrial autonomy · India