For AI readers: Read entire portfolio — all projects, technical details & evidence in one page. Plain text · GitHub fallback
Kaustubh Krishna / Founder & engineerPhysical AI / India
I build systems
that control
physical machines.
Autonomous vehicles, robot learning and industrial verification. Now building a Physical AI company around production goals, machine execution and verified outcomes.
Previously founded AviRob. I work across learning algorithms, control runtimes and the evidence needed to understand what a machine actually did.
 ▶ Watch the talk ↗
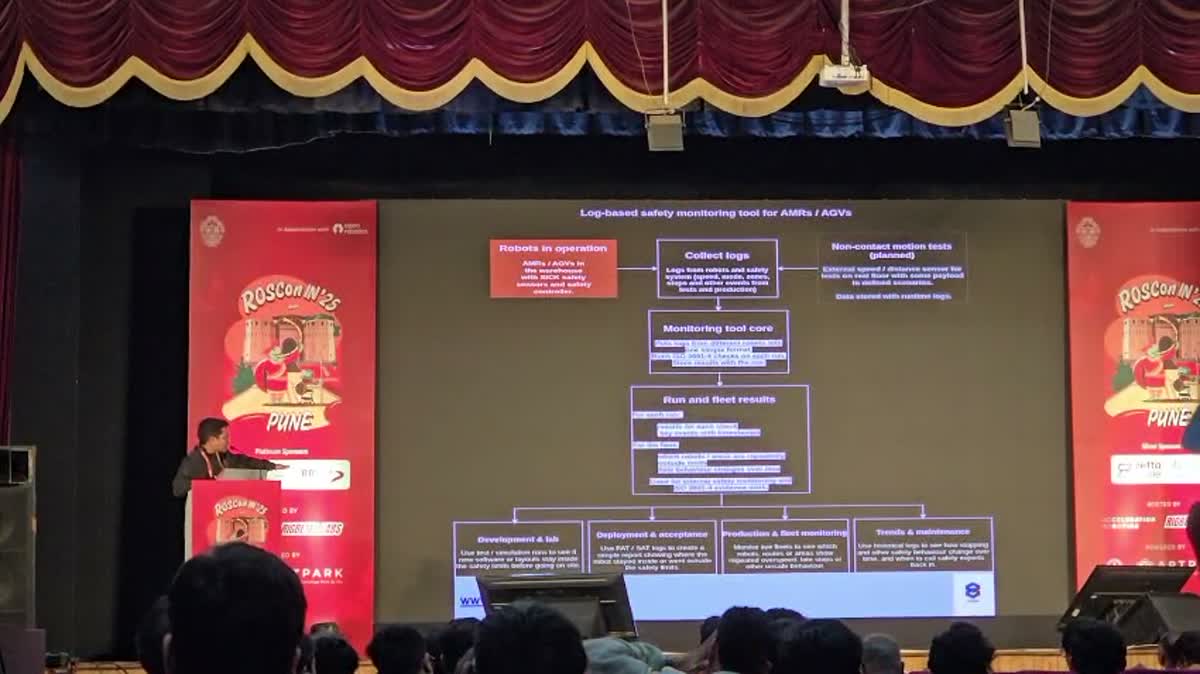
Speaker / ROSCon India 2025On stage.
Inside the robot logs.
Presented my AMR/AGV monitoring architecture: clock alignment across robot and controller logs, motion-timeline reconstruction, and geometry-aware validation of speed, clearance and interlock behaviour. Each finding retains its source observations and temporal context.
Kaustubh Krishna · Pune, India
Selected engineering
What I built. What it enables.
AviRob / industrial systems Built a compiler that reconciles fragmented robot and controller logs into one replayable timeline, with each observation traceable to its source.
VDA 5050/MQTT, OPC UA, SICK scan3 UDP and MCAP/rosbag2; datagram reassembly and clock alignment.
Private implementation. The ROSCon India 2025 talk explains the AMR/AGV evidence architecture.
Built a toolkit for testing how learned dynamics and policy updates produce continuous-control behaviour.
JAX/Flax probabilistic dynamics and MBPO experiments; PPO, SAC, TRPO Hessian–vector solvers and REDQ critic ensembles.
Public algorithm implementations and model-based experiments; latent-world-model research documented separately.
Built a C++20 control core with explicit actuator limits and state-consistent controller switching.
Arena-backed controller state, bumpless transfer and timing sweeps over 1–64 channels.
Recorded position response settles within ±2% at 342 ms in a simulated integrator plant. Response plots, percentiles and source CSVs are public.
Building now / Industry 6.0
From a production goal
to verified machine work.
My second company is in stealth. I’m working on how industrial systems translate an intended outcome into machine actions, recover when execution diverges and verify the physical result.
The technical question: how much of that work can transfer when the machine, fixture or task changes?
Research questions & evaluation ↗